Autonomy Software C++ 24.5.1
Welcome to the Autonomy Software repository of the Mars Rover Design Team (MRDT) at Missouri University of Science and Technology (Missouri S&T)! API reference contains the source code and other resources for the development of the autonomy software for our Mars rover. The Autonomy Software project aims to compete in the University Rover Challenge (URC) by demonstrating advanced autonomous capabilities and robust navigation algorithms.
Loading...
Searching...
No Matches
duckdb::PlanIndexInput Struct Reference
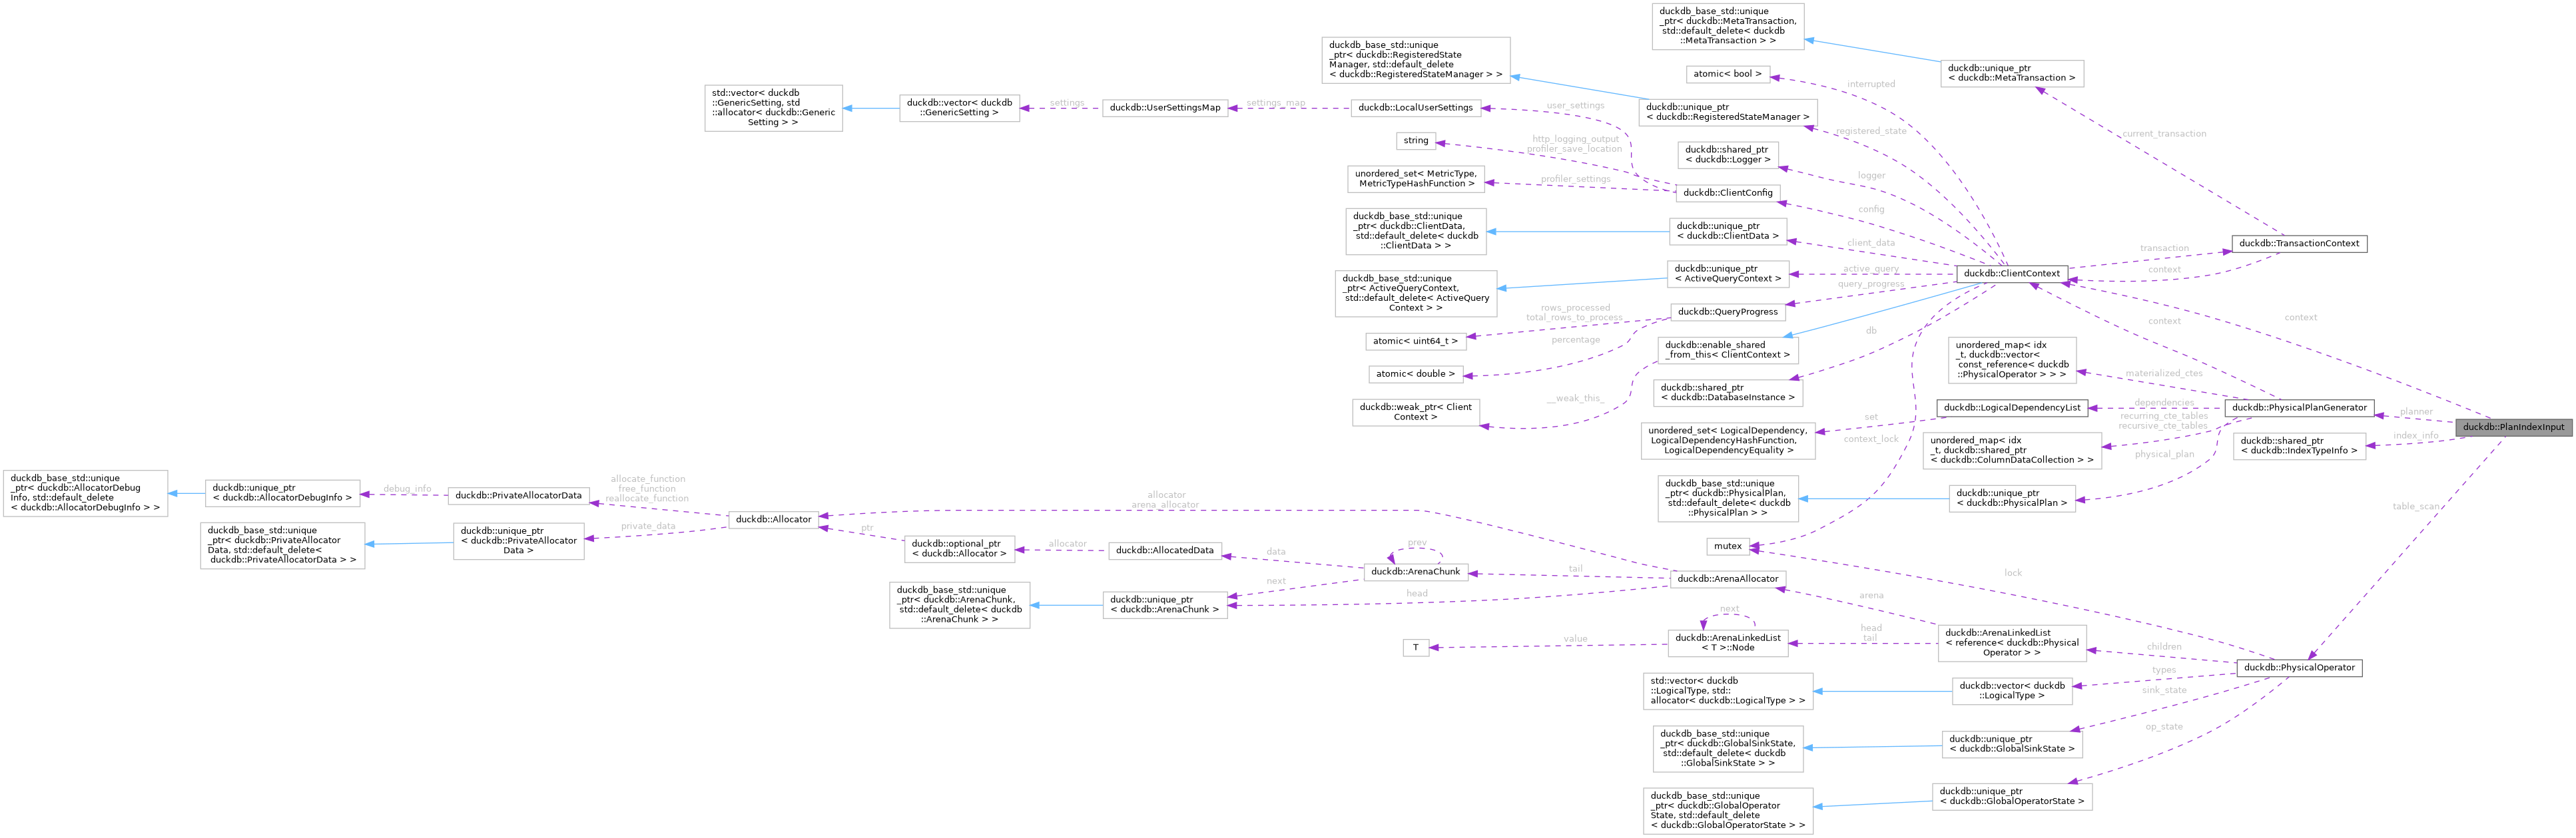
Collaboration diagram for duckdb::PlanIndexInput:

Public Member Functions

 PlanIndexInput (ClientContext &context_p, LogicalCreateIndex &op_p, PhysicalPlanGenerator &planner, PhysicalOperator &table_scan_p, shared_ptr< IndexTypeInfo > index_info_p=nullptr)
 

Public Attributes

ClientContext & context
 
LogicalCreateIndex & op
 
PhysicalPlanGenerator & planner
 
PhysicalOperator & table_scan
 
shared_ptr< IndexTypeInfo > index_info
 

Constructor & Destructor Documentation

◆ PlanIndexInput()

duckdb::PlanIndexInput::PlanIndexInput ( ClientContext &  context_p,
LogicalCreateIndex &  op_p,
PhysicalPlanGenerator &  planner,
PhysicalOperator &  table_scan_p,
shared_ptr< IndexTypeInfo >  index_info_p = nullptr 
)
inline
38421 : context(context_p), op(op_p), planner(planner), table_scan(table_scan_p),
38422 index_info(std::move(index_info_p)) {
38423 }

The documentation for this struct was generated from the following file: