Autonomy Software C++ 24.5.1
Welcome to the Autonomy Software repository of the Mars Rover Design Team (MRDT) at Missouri University of Science and Technology (Missouri S&T)! API reference contains the source code and other resources for the development of the autonomy software for our Mars rover. The Autonomy Software project aims to compete in the University Rover Challenge (URC) by demonstrating advanced autonomous capabilities and robust navigation algorithms.
Loading...
Searching...
No Matches
AutonomyGlobals.cpp File Reference

Sets up functions and classes used project wide. More...

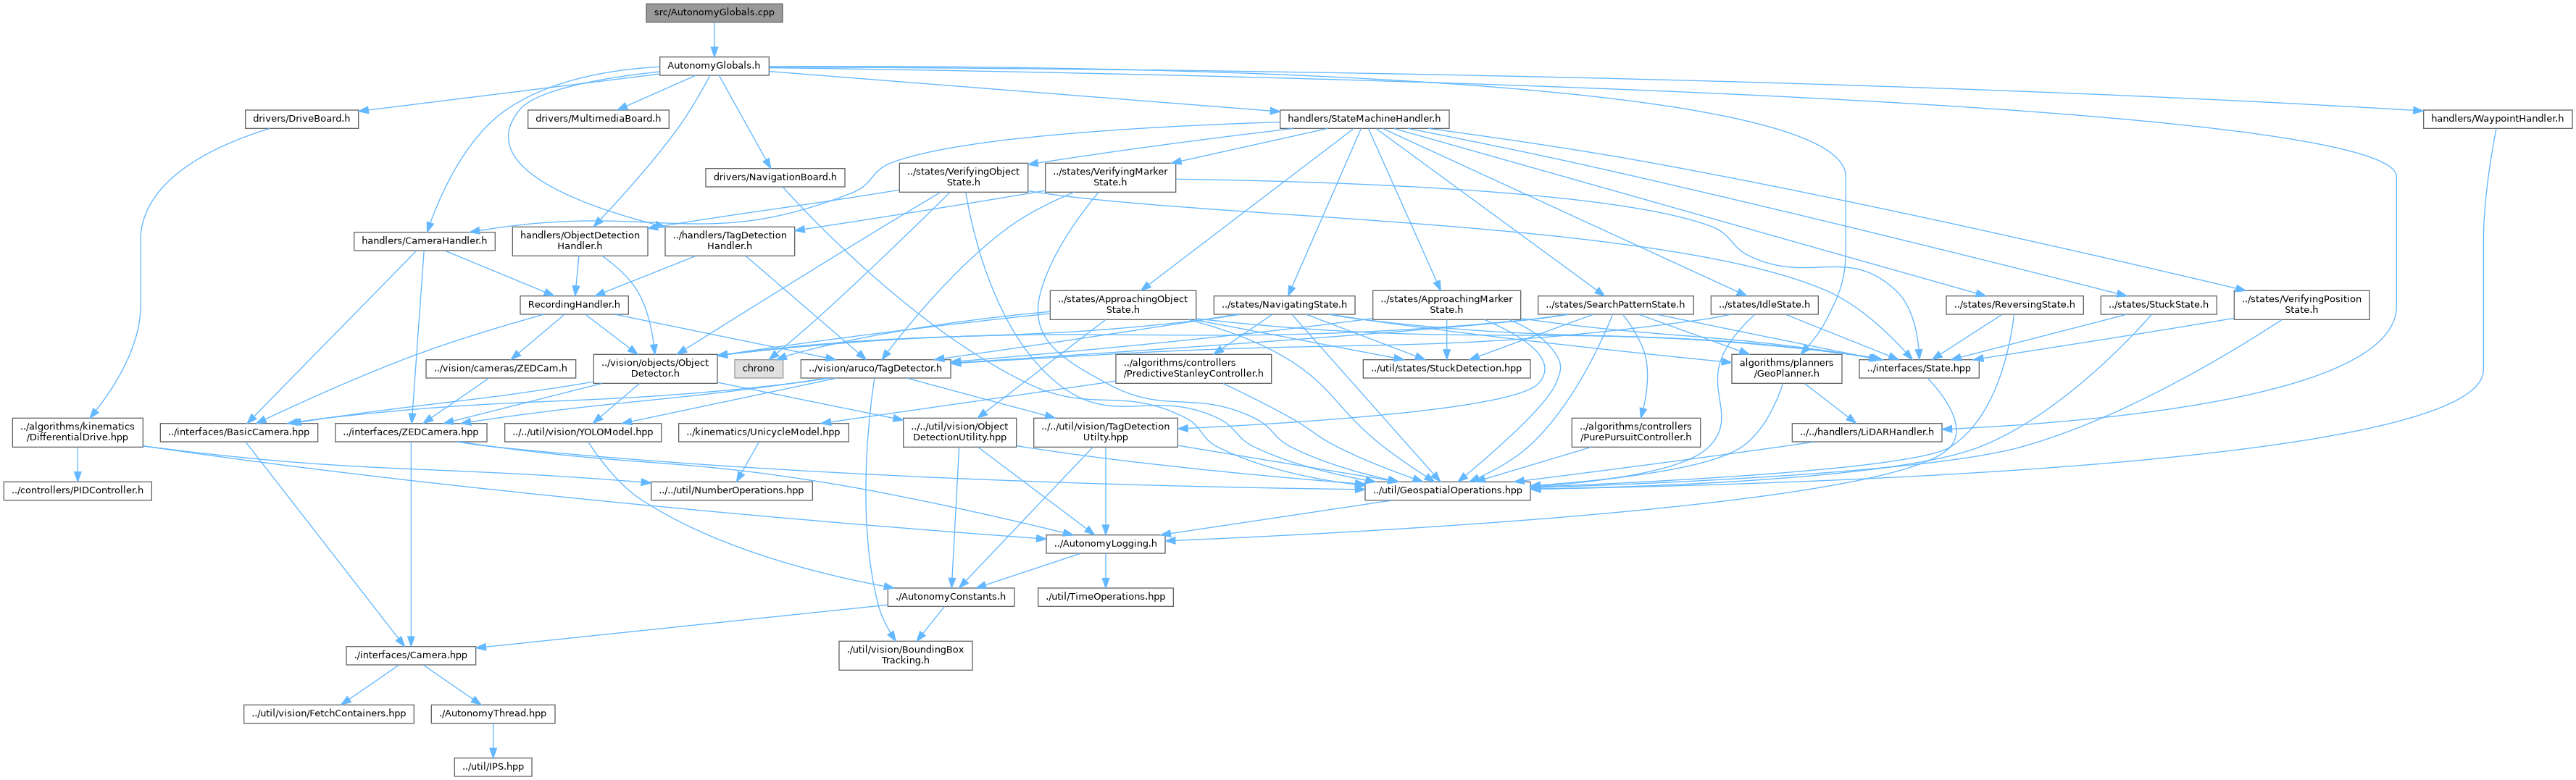
#include "AutonomyGlobals.h"
Include dependency graph for AutonomyGlobals.cpp:

Namespaces

namespace  globals
 Namespace containing all global types/structs that will be used project wide and ARE NOT SPECIFIC TO A CERTAIN CLASS.
 

Variables

WaypointHandler * globals::g_pWaypointHandler
 
LiDARHandler * globals::g_pLiDARHandler
 
CameraHandler * globals::g_pCameraHandler
 
TagDetectionHandler * globals::g_pTagDetectionHandler
 
ObjectDetectionHandler * globals::g_pObjectDetectionHandler
 
StateMachineHandler * globals::g_pStateMachineHandler
 
pathplanners::GeoPlanner * globals::g_pGeoPlanner
 
DriveBoard * globals::g_pDriveBoard
 
MultimediaBoard * globals::g_pMultimediaBoard
 
NavigationBoard * globals::g_pNavigationBoard
 

Detailed Description

Sets up functions and classes used project wide.

Author
Eli Byrd (edbgk.nosp@m.k@ms.nosp@m.t.edu), ClayJay3 (clayt.nosp@m.onra.nosp@m.ycowe.nosp@m.n@gm.nosp@m.ail.c.nosp@m.om)
Date
2023-06-20